Download PDF
Volumetric Positioning State (VPS / 5DVNS)
A Deterministic Framework for State-Based Positioning and Navigation
Prepared by: Hamdy Samy
Founder & IP Holder — 5DVNS
Date: February 2026
Executive Abstract
Positioning and navigation systems have historically been constructed around a single assumption: that
location is best represented as a point within an absolute reference frame. This assumption underlies global
navigation satellite systems (GNSS), inertial navigation systems (INS), simultaneous localization and
mapping (SLAM), and most contemporary autonomous navigation architectures.
This paper introduces a different premise.
Rather than treating position as a point in space, the Volumetric Positioning State (VPS / 5DVNS) models
position as a deterministic state embedded within a bounded volume, defined by geometric admissibility and
contextual integrity rather than absolute coordinates. Determinism is achieved by giving bounded uncertainty
sets and admissibility constraints. State validity evolves predictably without probabilistic correction
layers.
In this framework, position is not continuously corrected toward an external reference. Instead, positional
coherence is maintained through volumetric consistency under constraints. Guidance, stability, and
navigation outputs emerge from the persistence of admissible states over time.
The framework does not depend on privileged global reference frames, it does not require a persistent
global reference frame for state validity, it is robust to signal loss, vertical ambiguity, and map
unavailability. It reframes navigation from coordinate accuracy to state integrity, enabling coherent
operation across surface, subsurface, indoor, underwater, orbital, and non-physical domains.
This document formalizes the VPS state model, its invariance properties, and its interpretive shift,
without prescribing implementation details or domain-specific realizations.
1. Limits of Point-Based Positioning
Classical positioning systems represent location as a point:
P(t) = (x, y, z)
This formulation assumes:
- A stable external reference frame
- A privileged origin
- A continuous ability to correct drift
- A clear separation between position and uncertainty
While effective in open and well-instrumented environments, point-based positioning exhibits structural
fragility when:
- External references degrade or disappear
- Vertical ambiguity dominates (e.g., subsurface, indoor, underwater)
- Environments are dynamic, constrained, or unstructured
- Mapping is incomplete, outdated, or impossible
In such cases, systems compensate by layering probabilistic corrections, sensor fusion, or increasingly
complex maps—without addressing the underlying representational assumption.
The core limitation is not sensor quality or computation.
It is the choice of point as the primitive of
position.
2. From Coordinates to State Integrity
The VPS framework replaces point-based localization with state-based embedding.
Position is not asked as “Where am I?”
It is evaluated as “Is my current state
admissible within the volume I inhabit?”
Formally, position is expressed as:
S(t) = [x, y, d | V]
Where:
- x, y represent lateral embedding within a bounded manifold
- d represents scalar progression (depth, distance, phase, or corridor advancement)
- V is a volumetric context vector encoding: geometry, constraints, uncertainty,
stability, field or resonance behavior
The state is deterministic under bounded uncertainty.
Position emerges from volumetric consistency, not
absolute reference alignment.
In this model:
- Coordinates are observations, not authorities
- Sensors inform state evolution, but do not define position
- Drift is not eliminated, but made explicit and bounded
- Loss of external reference does not imply loss of coherence
Position becomes a property of state survivability under constraints over time.
3. Invariance Properties
The VPS formulation exhibits the following invariances:
- No dependence on fixed maps, magnetic north, or global orientation under constrained manifold embedding
- Robust to signal loss: coherence maintained without continuous external correction
- Robust to vertical ambiguity: depth and progression decoupled from Cartesian altitude
- Deterministic under bounded uncertainty: uncertainty is internalized, not externalized
- Domain-agnostic: applicable across surface, subsurface, indoor, underwater, orbital, and abstract
environments
These properties arise from the geometry of the state itself, not from redundancy or correction frequency.
4. Interpretive Shift
The framework introduces two fundamental transformations:
- From coordinate tracking → state integrity
- From position accuracy → positional confidence
Navigation guidance is not prescribed.
It emerges from the admissible evolution of states within
constraints.
This shifts navigation from optimization toward targets to maintenance of coherence.
Implementation Note
This document describes an operational-level construct.
Implementations may vary by domain, resolution, sensing modality, and risk profile. Certain structural
aspects of the framework are subject to prior art disclosures and active patent filings and are
intentionally described here at a conceptual level.
5. State Evolution and Admissibility
Within the VPS framework, navigation is the evolution of a state rather than the traversal of coordinates.
State evolution is governed by admissibility:
A state is valid if it remains geometrically and contextually consistent with the constraints encoded in V.
Formally, state transition does not seek an optimal target. It evaluates whether the next state remains
inside the admissible volume defined by:
- Geometric boundaries
- Environmental constraints
- Dynamic stability conditions
- Temporal progression limits
This introduces a critical distinction:
Trajectory is not planned in advance
Path viability is evaluated continuously
As long as the evolving state remains admissible, navigation proceeds. When admissibility degrades,
guidance emerges as a corrective signal—not toward a coordinate, but toward restored coherence.
In this sense, navigation is not command-driven.
It is constraint-driven.
6. Role of the Volumetric Context Vector (V)
The volumetric context vector V is not metadata.
It is a first-class component of the positional state. Unlike traditional systems where uncertainty,
constraints, or environmental factors are treated as error terms or auxiliary layers, VPS embeds them
directly into the state definition.
The vector V may encode, depending on domain and implementation:
- Geometric constraints (corridors, boundaries, exclusion zones)
- Stability margins (allowed deviation, tolerance envelopes)
- Uncertainty structure (bounded drift, sensor bias accumulation)
- Field behavior (electromagnetic, seismic, fluidic, or abstract fields)
- Resonance or persistence signatures
Crucially:
V does not describe the environment
V defines the conditions under which a state remains valid
This allows the system to reject impossible states deterministically, rather than correcting them
probabilistically after failure.
7. Emergent Outputs and Downstream Guidance
All operational outputs in VPS are derived, not prescribed.
Typical emergent outputs include:
- Navigation guidance within constrained volumes
- Corridor and path stability estimation
- Collision, failure, or instability risk metrics
- Decision confidence signals
- Autonomy control primitives
- Forward admissibility projection
These outputs are consequences of state evolution under constraints.
No map, waypoint, or route is required for these outputs to exist.
Guidance emerges when the system detects approaching loss of admissibility.
In this sense:
Guidance is a symptom
Stability is the objective
8. Separation of Integrity and Utility Layers
A defining architectural principle of VPS is the separation between:
- Integrity layers (state admissibility, coherence, bounded uncertainty)
- Utility layers (guidance, visualization, human interfaces)
This separation ensures that:
- The core state logic remains domain-invariant
- Consumer or operator guidance can vary freely
- Visualization does not influence state validity
- Human interpretation is downstream of machine coherence
This makes the framework suitable as a foundational positioning layer, rather than a domain-specific
navigation tool.
9. Applicability Beyond Physical Space
The VPS formalism does not require physical space.
Any system that satisfies the following conditions may be modelled:
- States exist inside bounded constraints
- Transitions occur over time or progression
- Admissibility can be evaluated deterministically
This allows the same formalism to apply to:
- Autonomous agents operating in abstract decision spaces
- Multi-agent coordination under shared constraints
- Graph traversal with viability conditions
- Non-spatial state systems where “position” represents coherence
In such cases, x, y, d need not correspond to physical dimensions.
They represent embedding,
progression, and phase inside a constrained manifold.
This extension is not metaphorical.
It is a direct consequence of the state definition.
10. Summary of the Shift
| Classical Navigation |
VPS / 5DVNS |
| Classical Navigation |
VPS / 5DVNS |
| Point-based |
State-based |
| Coordinate-driven |
Constraint-driven |
| Map-dependent |
Map-agnostic |
| Correction-centric |
Integrity-centric |
| Accuracy-focused |
Confidence-focused |
The VPS framework introduces a structural inversion: position corresponds to a state that remains within
the admissible set over time, not what is measured.
Closing Remark
The VPS framework does not compete with existing navigation systems.
It reframes the layer at which
positioning is defined.
It treats navigation not as the pursuit of coordinates, but as the maintenance of admissible state
evolution.
This makes it a domain-invariant admissibility layer for state-based positioning, autonomy, and reasoning
across domains.
Appendix A — Formal State Definition and Admissibility Model
A.1 State Space
Let the system evolve over continuous time t ∈ ℝ⁺.
Define a bounded manifold ℳ ⊆ ℝⁿ representing the admissible embedding domain.
The Volumetric Positioning State is defined as:
S(t) = (p(t), d(t), V(t))
where
- p(t) ∈ ℳ — lateral embedding
- d(t) ∈ ℝ — scalar progression parameter
- V(t) ∈ 𝒞 — context constraint vector
and 𝒞 is the constraint space.
A.2 Admissible Set
Define the admissible set:
𝒜 ⊆ ℳ × ℝ × 𝒞
A state is valid if:
S(t) ∈ 𝒜
Unlike classical positioning, validity is not defined by proximity to a reference coordinate but by
membership in the admissible set.
A.3 State Evolution
Let system evolution be governed by transition operator:
S(t+Δt) = Φ(S(t), u(t), η(t))
where
- u(t) — control input
- η(t) — bounded disturbance
The VPS condition requires:
Φ(S(t), u(t), η(t)) ∈ 𝒜 ∀ t
Navigation is therefore the maintenance of invariance of 𝒜.
A.4 Bounded Uncertainty
Instead of probabilistic error models, VPS uses bounded uncertainty sets:
η(t) ∈ ℰ(t)
with
ℰ(t) ⊆ ℝᵏ (compact)
Deterministic coherence exists if:
∀ η(t) ∈ ℰ(t), S(t) ∈ 𝒜
Thus position remains defined even under unknown disturbances.
A.5 Loss of Reference Frame
Let R(t) denote an external reference measurement.
Classical navigation requires:
lim ‖p̂(t) − p_R(t)‖ → 0 as t → ∞
VPS removes this requirement.
Instead, coherence requires only:
S(t) ∈ 𝒜 ∀ t
Therefore state validity is independent of the existence of R(t).
A.6 Guidance Emergence
Define admissibility margin:
γ(t) = dist(S(t), ∂𝒜)
Guidance is generated when:
γ(t) → 0
Control actions seek to increase admissibility margin rather than minimize coordinate error.
A.7 Observability Condition
A VPS state is observable if measurements constrain admissible set to a bounded subset:
|𝒜_t| < ∞
Position is therefore defined by constraint convergence rather than coordinate convergence.
A.8 Interpretation
Classical navigation:
Position = estimated coordinate
VPS:
Position = persistent membership in admissible set
Appendix B — Theorems (Statements Only)
Theorem 1 — Admissible State Invariance Under Bounded Disturbance (VPS Coherence)
Setup. Let the VPS state evolve as
S(t+Δt) = Φ(S(t), u(t), η(t))
with bounded disturbance η(t) ∈ ℰ(t), where ℰ(t) is compact for all t. Let 𝒜 ⊆ ℳ × ℝ × 𝒞 denote the
admissible set.
Assumptions.
- Φ is well-defined and continuous in (S, u, η) on the relevant domain.
- For every S ∈ 𝒜, there exists at least one control u ∈ 𝒰(S) such that Φ(S, u, η) ∈ 𝒜 ∀ η ∈ ℰ(t)
(robust admissible successor exists).
Statement. If S(t₀) ∈ 𝒜, then there exists a control policy u(·) such that
S(t) ∈ 𝒜 ∀ t ≥ t₀
i.e., admissibility is a robust forward-invariant property and coherence is preserved without
reference-frame correction.
Interpretation. VPS coherence is the persistence of state membership inside 𝒜 under
bounded disturbance.
Theorem 2 — Reference-Frame Independence of State Validity
Setup. Let R(t) denote any external reference signal (GNSS, map anchor, absolute heading,
etc.). Define VPS validity solely by admissible membership: S(t) ∈ 𝒜.
Assumptions.
- The admissible set 𝒜 and transition map Φ are defined without requiring R(t) as an input for state
definition (reference optional).
- When available, R(t) may refine the constraint vector V(t) but does not redefine 𝒜.
Statement. The truth value of “state is valid” is invariant to the presence or
absence of external reference:
(S(t) ∈ 𝒜) is well-defined even if R(t) ≡ ∅
Therefore, loss of external reference does not imply loss of state definability, only a potential change in
admissibility margin.
Corollary 2.1 (Graceful degradation). When R(t) is removed, coherence can persist as long
as the bounded disturbance set remains compatible with 𝒜.
Theorem 3 — Guidance Emergence From Boundary Proximity (Not Coordinate Error)
Setup. Define an admissibility margin:
γ(t) = dist(S(t), ∂𝒜)
where ∂𝒜 is the boundary of admissibility.
Assumptions.
- 𝒜 is closed and ∂𝒜 is well-defined.
- γ(t) is computable or lower-bounded from the available constraints V(t).
Statement. Any control policy that maintains or increases γ(t) produces navigation
guidance as a byproduct of preserving admissibility:
γ(t) ↓ 0 ⇒ emergent correction signal
and the corrective action is directed toward restoring admissibility (increasing γ), not minimizing
coordinate residuals.
Corollary 3.1 (Collision/risk as admissibility loss). Collision risk, instability risk, or
corridor failure correspond to trajectories that drive γ(t) toward zero.
Volumetric Positioning State (VPS / 5DVNS)
Author: Hamdy Samy
Date of Public Disclosure: January 18, 2026
Jurisdiction: Global (public disclosure)
This notice establishes prior art for the conceptual and theoretical foundations of the Volumetric
Positioning State (VPS), also referred to as the 5DVNS framework.
Scope of Disclosure
This prior art disclosure intentionally covers conceptual structure and formalism, not implementation.
The following elements are publicly disclosed and asserted as prior art:
1. Volumetric State Formalism
Position is defined as a state inside a bounded volume, not as a point in Cartesian space, formalized as:
S(t) = [x, y, d | V]
where positional meaning arises from volumetric consistency rather than absolute coordinates.
2. State Integrity Principle
Navigation, localization, and reasoning are governed by volumetric state integrity and admissibility under
bounded uncertainty, rather than continuous external correction.
3. Invariance Properties
The framework does not require a privileged global reference frame for state validity and is applicable
across physical and non-physical environments where agents operate under constraints.
4. Emergent Detection Principle
Detection, anomaly awareness, or risk indication is an emergent consequence of violations or stress within
volumetric state consistency, not a standalone detection method.
5. Guidance as Downstream Consumer
Navigation guidance, collision risk, and decision confidence are derived outputs, not primary objectives or
hard-coded rules.
6. Abstraction Shift
The framework shifts navigation and reasoning from:
- coordinate accuracy → positional confidence
- point estimation → state admissibility
- map dependence → geometric coherence
Explicit Exclusions
This disclosure does not reveal:
- implementation algorithms
- signal processing methods
- detection thresholds
- scoring functions
- system tuning or operational parameters
- hardware or software architectures
These remain protected under active and future intellectual property filings.
Purpose
This notice serves to:
- establish public conceptual prior art
- prevent re-patenting of the core abstraction under alternative terminology
- support defensive publication strategy
- clarify boundaries between concept and implementation
Statement
The author asserts that systems materially embodying the structural elements described above may fall
within the conceptual scope disclosed hereunder,
- represents position as a volumetric state,
- maintains coherence via geometric admissibility, and
- produces detection or guidance as an emergent integrity signal
are operating within the conceptual space established by this prior art.
This disclosure is publicly timestamped and intended to serve as prior art under applicable patent law,
including but not limited to the Paris Convention and relevant national statutes.
Corporate
Corporate & Legal Status
5DVNS Technologies SRL is a privately held European technology company incorporated under Belgian law.
The company develops spatial intelligence systems for industrial and dual applications.
All activities, partnerships, and deployments are conducted in accordance with applicable European
regulatory frameworks and international compliance standards.
Intellectual property
Intellectual Property
5DVNS Technologies SRL holds multiple patent filings covering its core methodologies, system
architectures, and volumetric navigation frameworks.
International patent application (PCT/EP2026/072683) Filed on 24/07/2026.
All underlying algorithms, VPS engines, volumetric models, and associated methodologies constitute
proprietary intellectual property and are protected under European and
international IP law.
Data governance
Data Governance
5DVNS systems are designed as offline-first architectures.
- No telemetry transmission
- No cloud dependency
- No third-party data integration
- No persistent data storage
All computations are executed locally within client-controlled environments.
5DVNS Technologies SRL does not collect, store, or retain operational or client data as part of its core
system design.
All engagements are governed by strict confidentiality, restricted-use agreements, and data
sovereignty principles.
Security
Security & Confidentiality
System deployments are structured to ensure:
- full client-side control of data environments
- isolation from external networks where required
- strict limitation of system access and usage scope
All technical exchanges, demonstrations, and evaluations are conducted under controlled disclosure
conditions and, where applicable, formal non-disclosure agreements (NDAs).
Compliance
Use & Compliance
5DVNS Technologies SRL develops technologies intended for industrial, scientific, and dual
applications, including navigation, spatial analysis, and operational resilience.
All deployments are subject to applicable legal, regulatory, and ethical frameworks within the
jurisdictions of operation.
What We Do
We provide three enterprise services.
1. VPS (Volumetric Positioning State)
Offline / deterministic / autonomous
VPS converts classical coordinates (latitude/longitude, decimal, or grid) into volumetric spatial
positions.
It allows resilient reference, redundancy, and indexing in:
- maritime operations
- offshore installations
- port development
- seabed analysis
- infrastructure corridors
- brownfield assessment
VPS is offline and self-contained. It does not rely on satellite signals or external
datasets.
2. SPARK (Toolset/Software Platform)
Interpretive enterprise analysis
Most forecasting and planning models fail when confronted with:
- fragmented supply chains
- irregular populations
- non-linear seasonal effects
- regional instability
- sudden events
VPS-SPARK stabilizes these environments by mapping how distortion accumulates spatially and how it
propagates through corridors and operational nodes.
We do predict. We complement ERP/AI. We correct the environments where those
tools break down.
3. Guided Enterprise Engagement
Confidential partnership model
We work with tier-one industrial partners in controlled, confidential formats:
- private technical briefings
- data intake workshops
- offline modeling cycles
Our engagements are designed to demonstrate value without exposing proprietary algorithms or internal
client infrastructure.
Subsea & Offshore Operations
Context
- GPS denied
- Low visibility
- High drift risk
- Complex 3D infrastructure
Use Cases
- ROV / AUV corridor stability mapping
- Subsea pipeline & cable clearance modeling
- Signal-degraded state coherence preservation
- Collision risk envelopes
- Dredging spatial integrity validation
We Deliver
- Admissible corridor models
- Drift instability alerts
- Depth-linked stability layers
- Clearance state validation
Subsurface & Energy Systems
Context
- Geological uncertainty
- Seismic ambiguity
- Multi-layer structural stress
Use Cases
- Subsurface corridor admissibility modeling
- Volumetric stress indicators
- Brownfield rehabilitation geometry
- Hydrogen / logistics corridor mapping
- Temporal instability windows
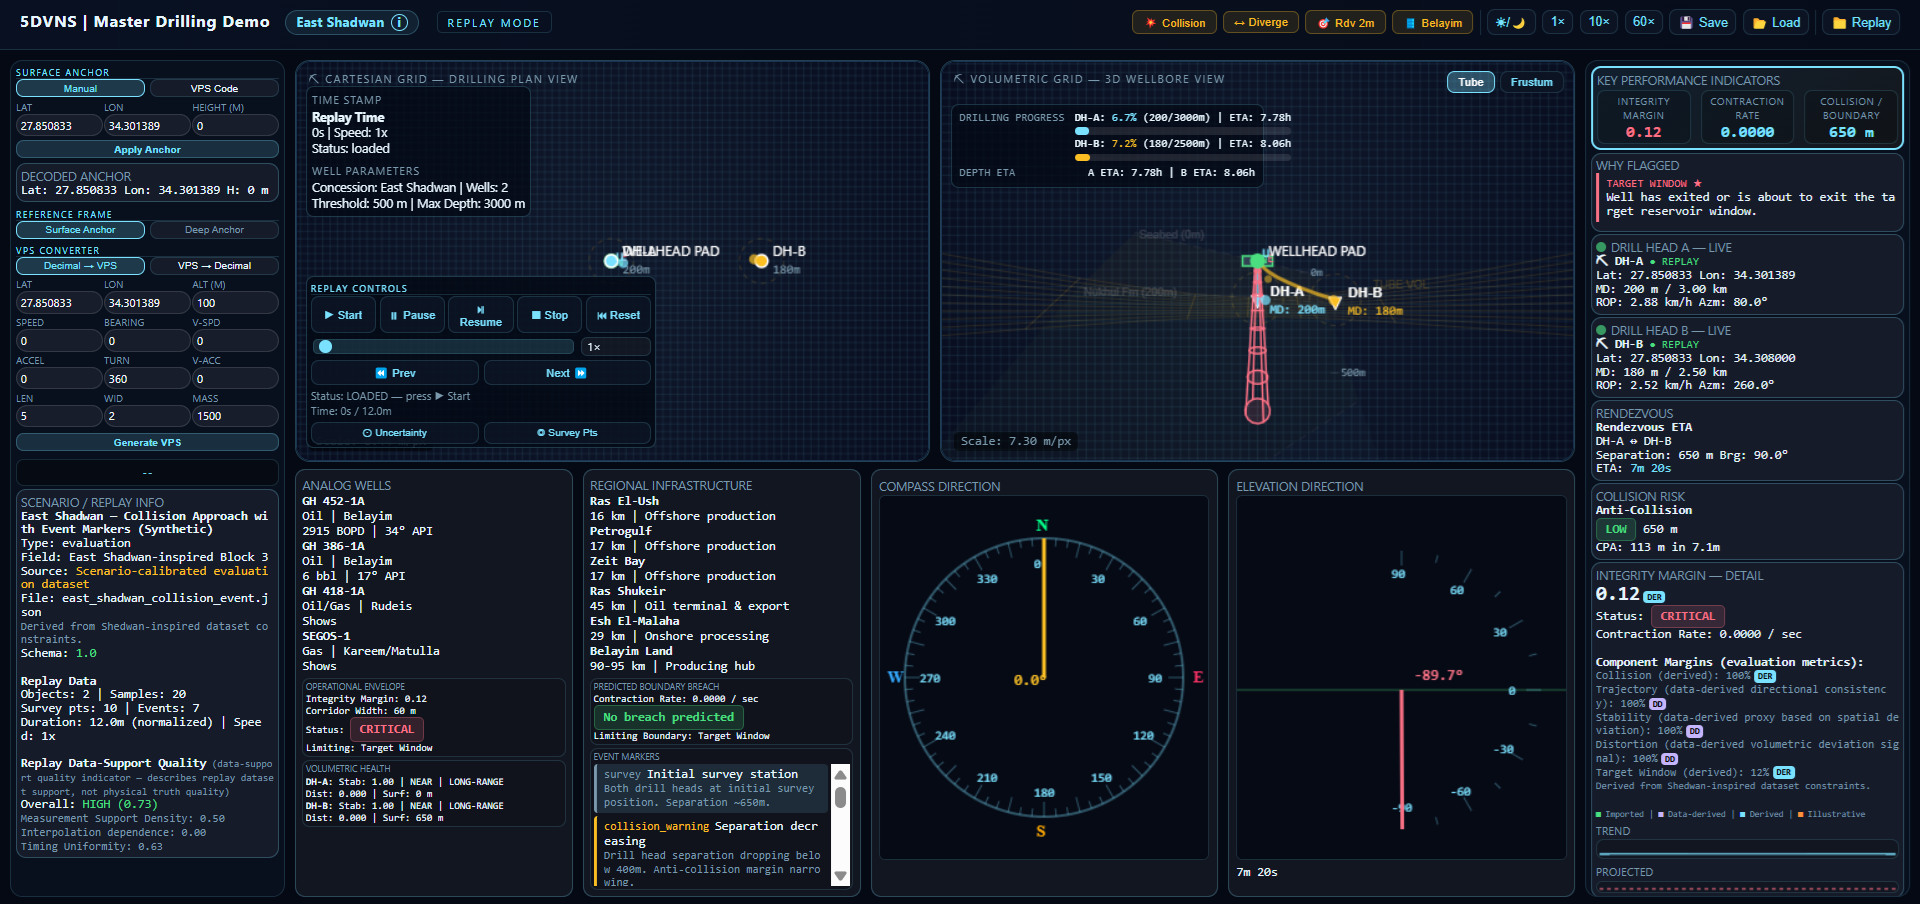
We Deliver
- Spatial distortion mapping
- Corridor stress vectors
- Predictive instability bands emerge strictly from boundary trajectory under constrained geometry
- Decision-layer overlays for drilling & planning
Space & Orbital Environments
Context
- Operation under degraded or delayed external reference correction
- Communication delay
- Navigation under sparse references
Use Cases
- Orbital corridor modeling
- Signal-degraded trajectory coherence
- Proximity operation state validation
- Autonomous volumetric positioning
We Deliver
- Admissible orbital envelopes
- Motion-aware trajectory integrity
- Collision risk state monitoring
- Frame-agnostic state integrity modeling
Operational Integrity Outcomes
- Maintains bounded drift under GNSS loss
- Preserves corridor coherence in complex 3D infrastructure
- Derives collision risk from boundary proximity
- Enables offline deterministic autonomy
Extended Applications
The Volumetric Coordinate can be adapted to systems that represent position as bounded volumetric state
membership and derive navigation or detection signals from admissibility evaluation and embody structural
elements disclosed herein.
Traditional navigation systems represent position as a point in Cartesian space, defined by coordinates
that must be continuously corrected against external references.
The VPS framework replaces this assumption.
In VPS, position is modeled as a state within a bounded volume, not as an absolute coordinate. A position
is considered valid if it remains coherent within geometric, environmental, and operational constraints.
This means positional integrity is maintained through volumetric consistency, rather than coordinate
accuracy. The system evaluates whether an object remains in a valid spatial state, even when absolute
references are unavailable, degraded, or conflicting.
VPS represents position as a structured spatial state composed of:
- Lateral embedding within a bounded manifold
- Depth or progression, representing corridor distance or volumetric advancement
- Volumetric context, capturing geometry, constraints, uncertainty, stability, and field behavior
This structure defines where an entity exists in relation to its environment, rather than where it exists
on a global map.
The purpose of this structure is not measurement precision, but state validity and continuity under
constrained and uncertain conditions.
VPS is deterministic not because it eliminates uncertainty, but because it operates within bounded
uncertainty.
Determinism is achieved through geometric and constraint coherence, rather than continuous correction from
external signals or reference frames.
As long as the system remains within a valid volumetric corridor, positional continuity is preserved.
Signal loss, ambiguity, or degradation do not invalidate the state.
This allows stable operation in environments where traditional navigation systems become unstable or fail
entirely.
VPS does not produce predefined or hard-coded outputs.
Navigation guidance, corridor stability, collision risk, trajectory confidence, and decision signals are
derived properties of the volumetric state.
These outputs emerge from the integrity of the spatial state and its constraints, rather than from
prediction models, rule engines, or optimization targets.
VPS does forecast outcomes. It maintains valid spatial context so downstream systems and operators can
act with confidence.
VPS is not a GIS system. It does not depend on maps or spatial databases.
VPS is not SLAM. It does not build or require persistent environmental models.
VPS is not a cloud analytics platform. It operates fully offline without telemetry.
VPS is not a surveillance or tracking system. It does not collect, transmit, or store operational data.
VPS is a volumetric positioning framework focused on maintaining spatial state integrity in constrained
environments.
Volumetric Positioning State
VPS stands for Volumetric Positioning State — a volumetric positioning framework designed
to preserve spatial state integrity in constrained environments. A deterministic admissibility engine for
bounded state evolution in degraded-reference complex environments.
Position as a State (NOT a Coordinate)
Traditional navigation systems represent position as a point in Cartesian space, defined by coordinates
that must be continuously corrected against external references.
The VPS framework replaces this assumption.
In VPS, position is modeled as a state within a bounded volume, not as an absolute coordinate. A position
is considered valid if it remains coherent within geometric, environmental, and operational constraints.
Positional integrity is therefore maintained through volumetric consistency, rather than coordinate
accuracy.
Formal State Structure (Conceptual)
VPS represents position as a structured spatial state composed of:
- lateral embedding within a bounded manifold
- depth or progression along a corridor or volume
- volumetric context capturing geometry, constraints, uncertainty, and stability
This structure defines where an entity exists in relation to its environment, rather than where it exists
on a global map.
The objective is state validity and continuity under constrained and uncertain conditions.
Determinism Under Bounded Uncertainty
VPS is deterministic not because it eliminates uncertainty, but because it operates within bounded
uncertainty.
Determinism is achieved through geometric and constraint coherence, not through continuous correction from
external signals or fixed reference frames.
As long as the spatial state remains valid within its volumetric corridor, positional continuity is
preserved even during signal loss or ambiguity.
Derived Outputs (Not Hard-Coded)
VPS does not produce predefined or hard-coded outputs.
Navigation guidance, stability indicators, collision risk, trajectory confidence, and decision signals are
derived properties of the volumetric state.
These outputs emerge from state integrity and constraint satisfaction, not from prediction engines or
optimization logic.
VPS does not forecast outcomes. It maintains valid spatial context.
What VPS Is Not
VPS is not a GIS system and does not depend on maps or spatial databases.
VPS is not SLAM and does not build persistent environmental models.
VPS is not a cloud analytics platform and operates fully offline.
VPS is not a surveillance or tracking system and does not collect or transmit operational data.
VPS is a volumetric positioning framework designed to preserve spatial state integrity in constrained
environments.
Volumetric Positioning State (VPS / 5DVNS)
A Deterministic Framework for State-Based Positioning and Navigation
Volumetric Positioning State (VPS / 5DVNS) introduces a foundational shift in how position and navigation
are defined.
Rather than representing position as a point within an absolute reference frame, VPS models position as a
deterministic state embedded within a bounded volume, defined by geometric admissibility and contextual
integrity.
In this framework, position is not continuously corrected toward an external reference. Positional
coherence is preserved through volumetric consistency under constraints, allowing navigation, guidance, and
stability signals to emerge naturally from valid state evolution.
Limits of Point-Based Positioning
Classical navigation systems treat position as a point in space, assuming:
- a stable external reference frame
- a privileged global origin
- continuous correction of drift
- separation between position and uncertainty
These assumptions break down in environments where references degrade, vertical ambiguity dominates, or
maps are incomplete or unavailable.
The limitation is not sensor quality or computation.
It is the choice of point-based representation as the primitive of position.
From Coordinates to State Integrity
VPS replaces point-based localization with state-based embedding.
Position is no longer asked as "Where am I?"
It is evaluated as "Is my current state admissible within the volume I inhabit?"
Coordinates become observations rather than authorities.
Sensors inform state evolution, but do not define position.
Drift is not eliminated, but made explicit and bounded.
Loss of external reference does not imply loss of coherence.
Position becomes a property of state survivability under constraints over time.
Invariance Properties
The VPS framework exhibits the following invariance:
- Does not require a privileged global reference frame to state validity.
- Robustness to signal loss and degraded sensing
- Robustness to vertical ambiguity and depth uncertainty
- Deterministic behavior under bounded uncertainty
- Applicable across physical and non-physical environments
These properties arise from the geometry of the state itself, not from redundancy or correction frequency.
Interpretive Shift
The framework introduces two fundamental transformations:
- From coordinate tracking → state integrity
- From position accuracy → positional confidence
Navigation guidance is not prescribed in advance.
It emerges from the admissible evolution of states within constraints.
This shifts navigation from optimization toward targets to maintenance of coherence.
Emergent Outputs and Guidance
All operational outputs in VPS are derived, not prescribed.
Typical emergent outputs include:
- navigation guidance in constrained volumes
- corridor and path stability estimation
- trajectory confidence and risk indicators
- collision or failure risk metrics
- decision confidence signals
Guidance emerges when the system detects approaching loss of admissibility.
Stability is the objective.
Separation of Integrity and Utility Layers
VPS enforces a strict separation between:
- Integrity layers, responsible for state admissibility and coherence
- Utility layers, responsible for guidance, visualization, and interfaces
This ensures that visualization and human interpretation remain downstream of machine coherence, preserving
domain invariance and system integrity.
Applicability Beyond Physical Space
The VPS formalism does not require physical space.
Any system where states exist inside bounded constraints and transitions occur over time may be modeled
using the same framework.
This includes abstract decision spaces, multi-agent coordination, and non-spatial state systems where
position represents coherence rather than location.
This extension is not metaphorical.
It is a direct consequence of the state definition.
Summary of the Shift
VPS introduces a structural inversion of classical navigation:
- Point-based → State-based
- Coordinate-driven → Constraint-driven
- Map-dependent → Map-agnostic
- Correction-centric → Integrity-centric
- Accuracy-focused → Confidence-focused
Position corresponds to a state that remains within the admissible set over time, not what is measured.